Model a desk robot arm
This tutorial builds a small desk robot arm: a base, a shoulder, two arm links, a wrist and a gripper with two jaws. Then an assembly puts the parts on joints that turn within limits and holds them together with bolts, nuts and screws from the standard parts library. It is long, so it comes in seven chapters, one for each part and one for the assembly, with a picture of every step.
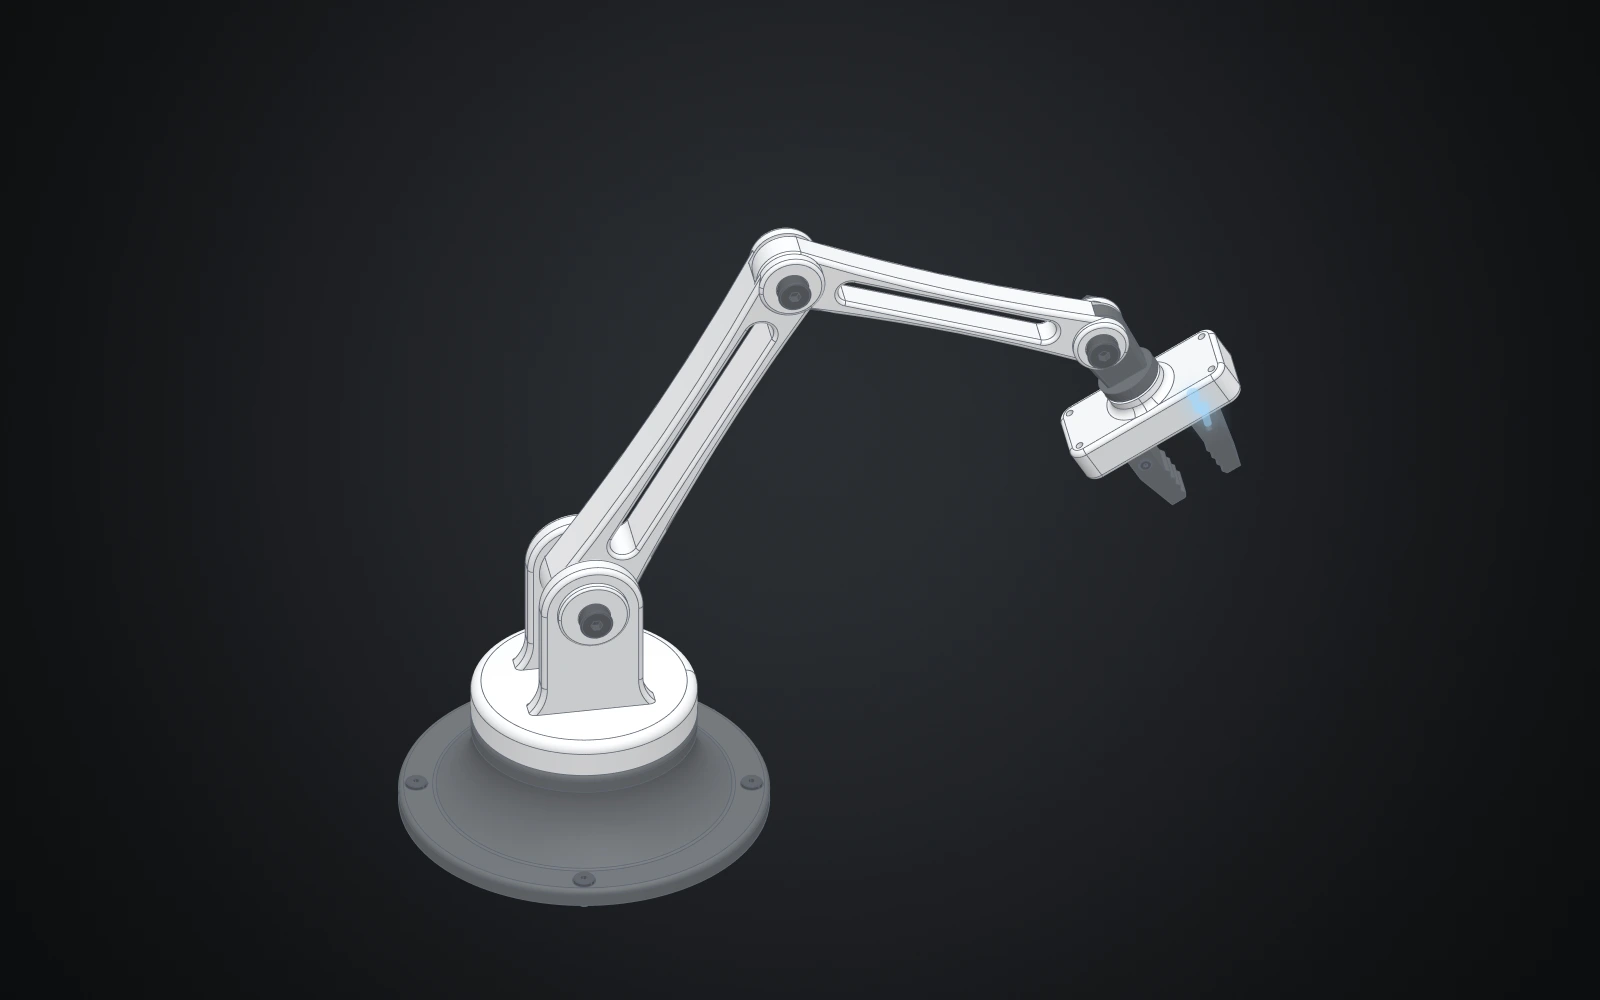
Along the way you will:
- revolve a profile into a round part, and mirror a feature to make its twin;
- drill holes sized for a metric screw, counterbore included, and mark them with connectors, the places parts attach;
- make one link document whose parameters let it serve as both arm segments;
- put parts on joints that turn within limits;
- insert a bolt and a nut from the standard parts library, and fasten every hole of a set with screws in one step.
It helps to have done Make your first part first.
Play it in the Designer
Open Help > Tutorials and press Start beside Model a desk robot arm. The card rings each control, moves on when you make the step, and Do it makes a step for you. Making the first steps of a part by hand and the rest with Do it is a quick way to see how a whole part comes together.
The chapters
Each part starts a new document, and each chapter ends with a picture of what its steps make. The step numbers run through the whole tutorial, as they do on the card.
- The base: a revolved pedestal with holes for M5 screws.
- The shoulder: a clevis made by mirroring one cheek, joined to a revolved drum.
- The link: one document with five parameters, used for both arm segments.
- The wrist: a knuckle with a tool flange.
- The gripper: a palm with two jaw rails and a blended neck.
- The jaw: a serrated finger on a sliding carriage.
- The assembly: the parts on joints with limits, a bolt and a nut through each pivot, and screws fastened into every hole set.
Verified against the product in October 2026